What is it about?
Microgrippers usually force a choice: either fine force resolution with tiny displacements, or large strokes at prohibitive power. We developed a MEMS gripper combining millinewton-level gripping force, millimeter-scale displacement, and low power consumption in a single device. This balance of force, stroke, and efficiency targets practical pick-and-place handling of delicate macro-micro objects — assembling components, manipulating biological samples, and bridging the gap between microscopic actuators and real-world objects.
Featured Image
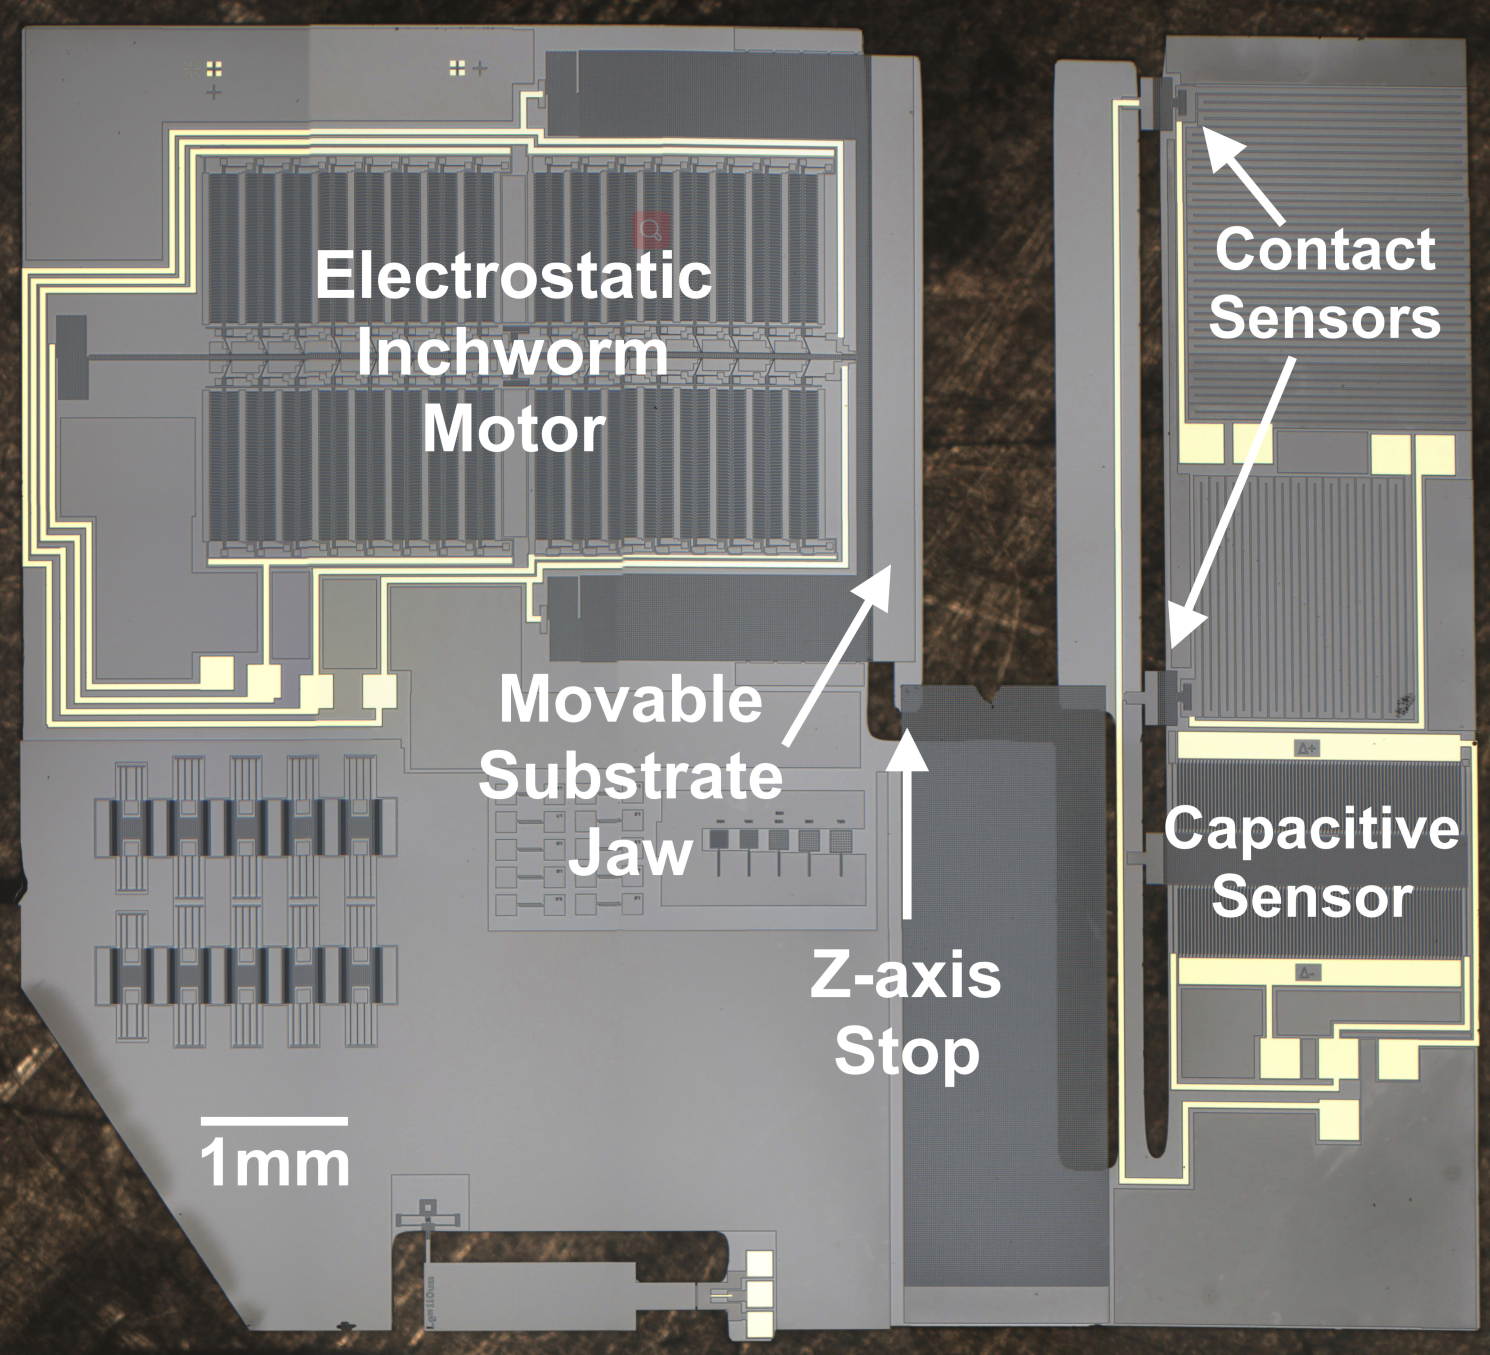
Photo by on Unsplash
Why is it important?
Handling objects that are neither microscopic nor comfortably macroscopic — from electronic microcomponents to small biological specimens — is a genuine automation gap. A gripper that is strong, long-reaching, and low-power at MEMS scale makes robotic micromanipulation practical outside specialized labs.
Perspectives
The hard part was not making the gripper move; it was making it strong and gentle at the same time. That tension shaped every design iteration.
Professor Wei Li
Huazhong University of Science and Technology
Read the Original
This page is a summary of: 15 Millinewton Force, 1 Millimeter Displacement, Low-Power MEMS Gripper, January 2020, Institute of Electrical & Electronics Engineers (IEEE),
DOI: 10.1109/mems46641.2020.9056128.
You can read the full text:
Contributors
The following have contributed to this page